Robotic Arm FK & IK Solver
A forward and inverse kinematics solver for a 6DOF robotic arm, built in MATLAB and deployed through ROS2.
Project Details / Background
I designed a forward and inverse kinematic solver for a robotic arm (ABB IRB-1400) in MATLAB, then wired the solver into ROS subscribers so it can solve for any set of joint angles or a desired end-effector position and orientation as they're published.
The solver isn't locked to that one arm. The programs can be adjusted with new frame positions to work with any 6DOF serial robot with revolute joints, making it reusable across different robotic systems.
Image Gallery
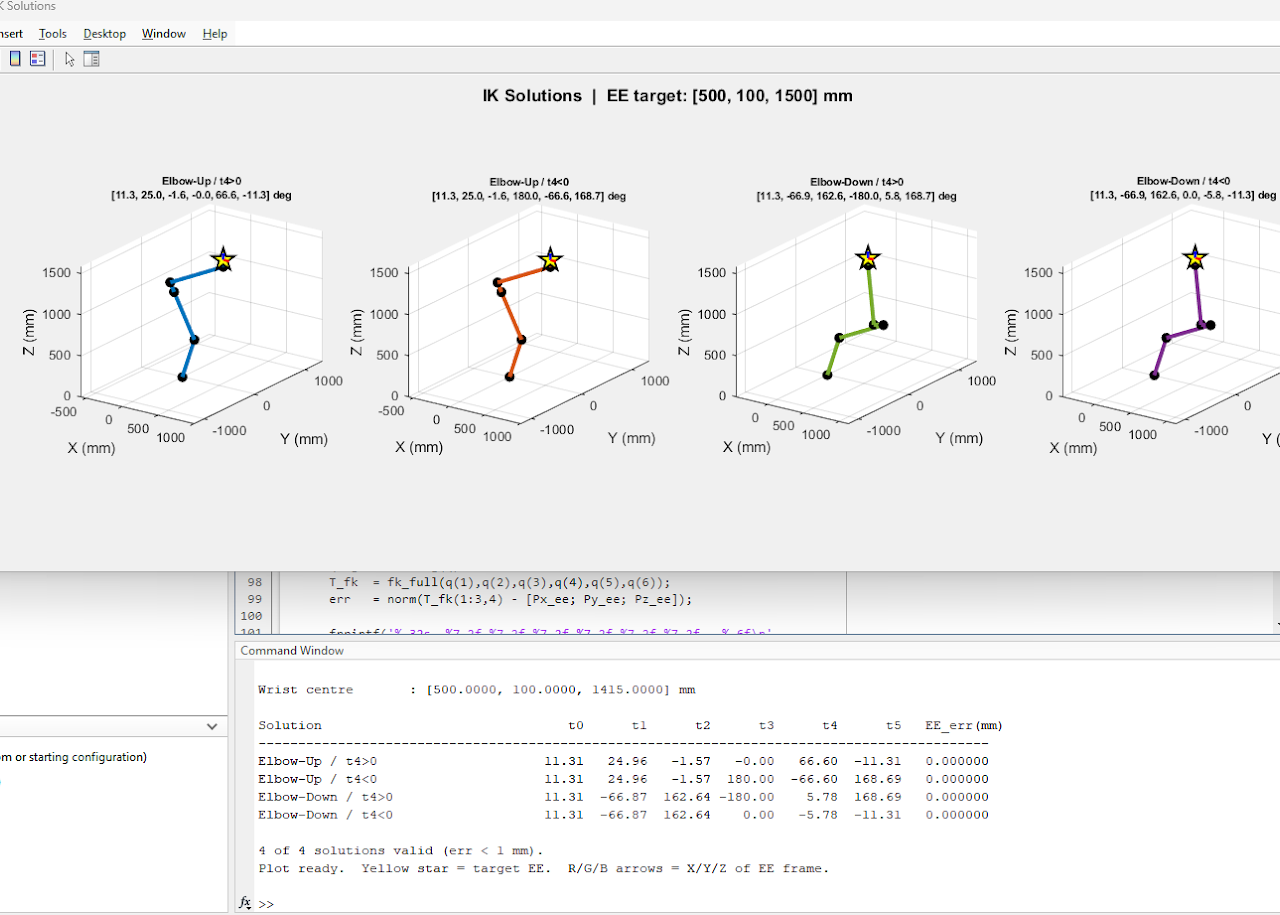 MATLAB IK solutions for a target end-effector position: all 4 elbow-up/elbow-down configurations
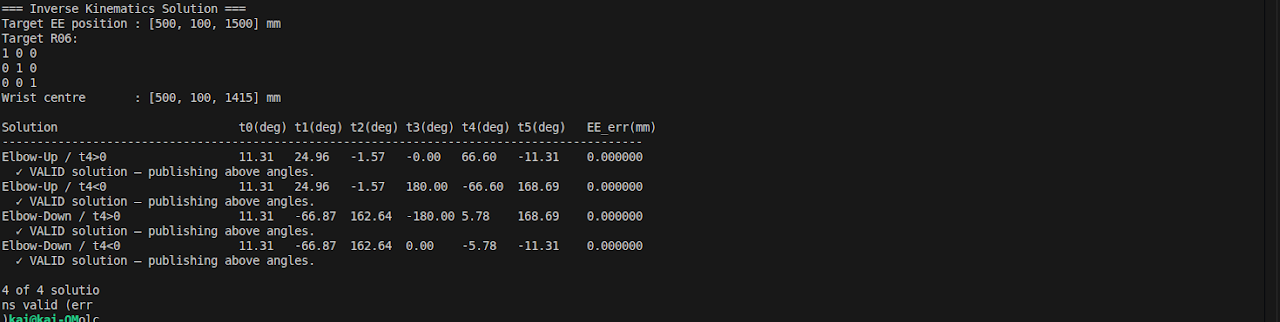 ROS2 node publishing the IK solution